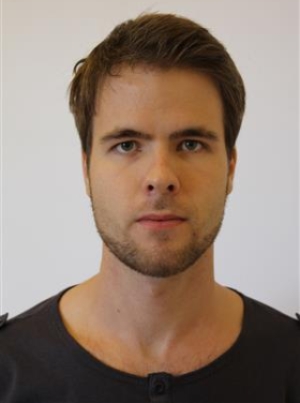
Maksis Celitāns
Mg. sc. ing.
Research assistant
Maksis Celitāns has been working at the Institute of Electronics and Computer Science since 2019. He graduated from Riga Technical University (Riga, Latvia), where he obtained a Professional Master’s degree in Electrical Engineering in 2016, specialising in Computer Control of Electrical Technologies at the Faculty of Power and Electrical Engineering. In 2020, he earned a Master’s degree in Engineering Sciences in the study programme Intelligent Robotic Systems at the Faculty of Computer Science and Information Technology.
Maksis’ research focuses on vehicle and system perception based on data from various sensor modalities, with particular emphasis on enhancing environmental perception through shared perception and cooperative interaction among multiple systems. In his free time, Maksis enjoys spending time outdoors, is passionate about rock climbing and hiking, and is also interested in 3D modelling and 3D printing.
Projects
6 results
- A mosaic of essential electronic components and systems (ECS) for our automated digital future in industry and mobility (MOSAIC) 01.07.2025 – 30.06.2028 Completed
- Ensuring European ECS Value Chain Sovereignty through Shaping the Future of ECS for Automotive Applications (ShapeFuture) 01.05.2024 – 30.04.2027 Completed
- Intelligent, Safe and Secure Connected Electrical Mobility Solutions: Towards European Green Deal and Seamless Mobility (EcoMobility) 01.05.2023 – 30.04.2026 Completed
- Automotive Intelligence for/at Connected Shared Mobility (AI4CSM) 01.05.2021 – 30.04.2024 Completed
- Framework of key enabling technologies for safe and autonomous drones applications (COMP4DRONES) 01.09.2019 – 31.08.2022 Completed
- Multidimensional room and area scanning system. (TADSS) 01.09.2019 – 31.08.2021 Completed
Publications
- 2025
Ground Segmentation Method Based on Polar Grid for 3D LiDAR Point Cloud(opens in a new window)
Katrīna Tupule, Maksis Celitāns, Kaspars Ozols
2025 22nd International Conference on Networking, Sensing, and Control (ICNSC), p. 377-383, IEEE
- 2025
A Distributed Time-of-Flight Sensor System for Autonomous Vehicles: Architecture, Sensor Fusion, and Spiking Neural Network Perception(opens in a new window)
Edgars Lielamurs, Ibrahim Sayed, Andrejs Cvetkovs, Rihards Novickis, Anatolijs Zencovs, Maksis Celitans, Andis Bizuns, George Dimitrakopoulos, Jochen Koszescha, Kaspars Ozols
Electronics, Vol. 14 (7), MDPI
- 2025
ShapeFuture - Technical Progress After Year 1(opens in a new window)
Druml, N., Gschwandtner, M., Jeannin, M., Matischek, R., Lielamurs, E., Celitans, M., Ozols, K., Demiralay, N., Tayfur, B., Gulbas, I. S., Kucuk, N., Kiyat, I., Nasolo, Y., Brandt, J., Pütz, N. C., Bartz-Beielstein, T., Isola, J., Mandic, N., Flamigni, F., Kuehhas, A., Brilli, G., Burgio, P., Paolieri, G., Villagra, J., Cueto, Á. F., Sánchez, J. A., Sini, J., Violante, M., Giraudi, L., Santero, P., Kölbel, U., Schaffenroth, M., Sjövall, P., Vanne, J., Larsen, M., Yilmaz, N. G., Yengin, Z. U., Dimitrakopoulos, G.
28th Euromicro Conference on Digital System Design (DSD), p. 350-359
- 2021
Ultra-Wideband Pulse Radar Mounted on an Unmanned Aerial Vehicle for the Monitoring of Moving Objects(opens in a new window)
V.Aristov, E.Lobanovs, R.Maliks, M.Celitans, J.Simanovichs, S.Bondars, R.Gailis
Automatic Control and Computer Sciences, Vol. 54 (4), p. 396 - 405, Pleiades Publishing