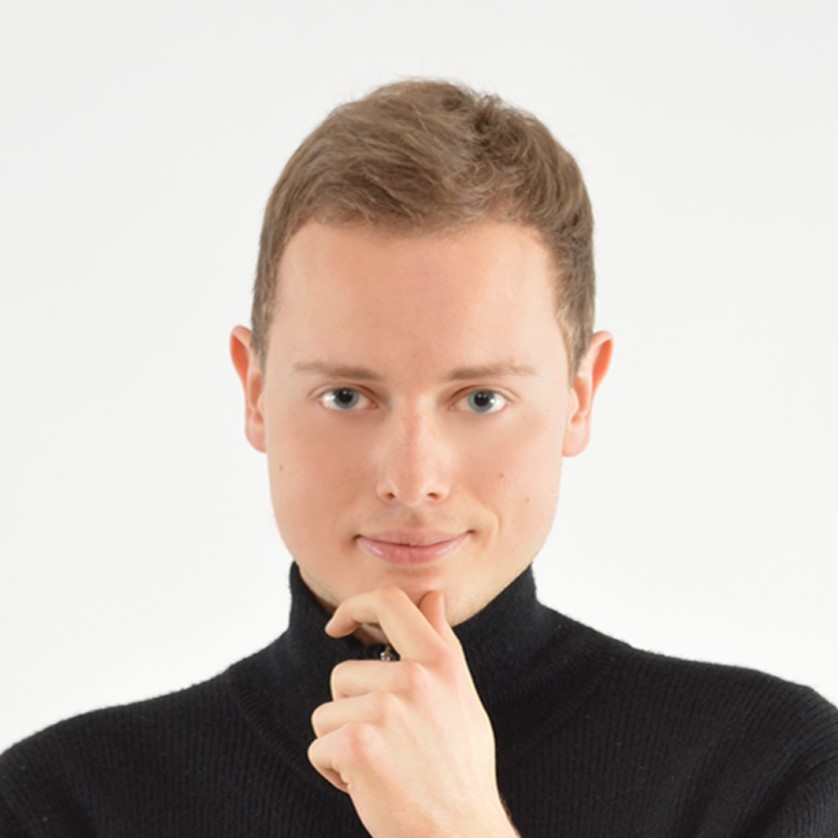
Oskars Teikmanis
M. Sc.
Researcher
Oskars Teikmanis joined EDI in September 2021 and became a researcher in July 2023. He received his B. Sc. degree in Engineering Science from the Technical University of Munich (TUM) in 2016. He continued his studies at TUM to obtain an M. Sc. degree in Mechatronics and Information Technology in 2019, completing his master’s thesis in robot localization at the German Aerospace Center (DLR). After having worked in the field of autonomous driving in Munich for several years, Oskars moved to Latvia.
His current research interests include the application of differentiable physics simulators for gradient-based control policy learning, and simulation-to-reality strategies for transferring such policies to physical robots.
Related publications:
Projects
6 results
- Artificial Intelligence in Manufacturing leading to Sustainability and Industry 5.0 (AIMS5.0) 01.05.2023 – 30.04.2026 Completed
- Metodes, modeļi un rīki enerģētikas sistēmu viedai attīstībai (MESVA) 01.01.2025 – 31.03.2026 Completed
- One Step Open DBL solution (openDBL) 01.01.2023 – 31.12.2025 Completed
- Smart Materials, Photonics, Technologies, and Engineering Ecosystem (MOTE) 01.01.2023 – 31.12.2024 Completed
- Automotive Intelligence for/at Connected Shared Mobility (AI4CSM) 01.05.2021 – 30.04.2024 Completed
- 5th Generation connected and automated mobility cross-border EU trials (5G-Routes) 01.09.2020 – 31.08.2023 Completed
Publications
- 2024
Learning to Move Objects With Fluid Streams in a Differentiable Simulation(opens in a new window)
Kārlis Freivalds, Laura Leja, Oskars Teikmanis
2024 7th Iberian Robotics Conference, ROBOT 2024, IEEE
- 2024
Learning Fluid-Directed Rigid Body Control(opens in a new window)
Kārlis Freivalds, Oskars Teikmanis, Laura Leja, Rodions Saltanovs, Ralfs Āboliņš
Machine Learning and the Physical Sciences, NeurIPS
- 2024
Shaping Flames with Differentiable Physics Simulations(opens in a new window)
Laura Leja, Oskars Teikmanis, Kārlis Freivalds
"Machine Learning and the Physical Sciences" at NeurIPS 202, NeurIPS
- 2024
Learning to Move Objects with Fluid Streams in a Differentiable Simulation(opens in a new window)
Kārlis Freivalds, Laura Leja, Oskars Teikmanis
ROBOT 2024 7th Iberian Robotics Conference, IEEE,
- 2023
Automated Vehicle Platform with Connected Driving Capabilities
Oskars Teikmanis, Aleksandrs Levinskis, Andris Ivars Mackus, Artis Rušiņš, Amr Elkenawy, Marta Tropa, Modris Greitans
2023 IEEE International Conference on Intelligent Transportation Systems (ITSC), IEEE