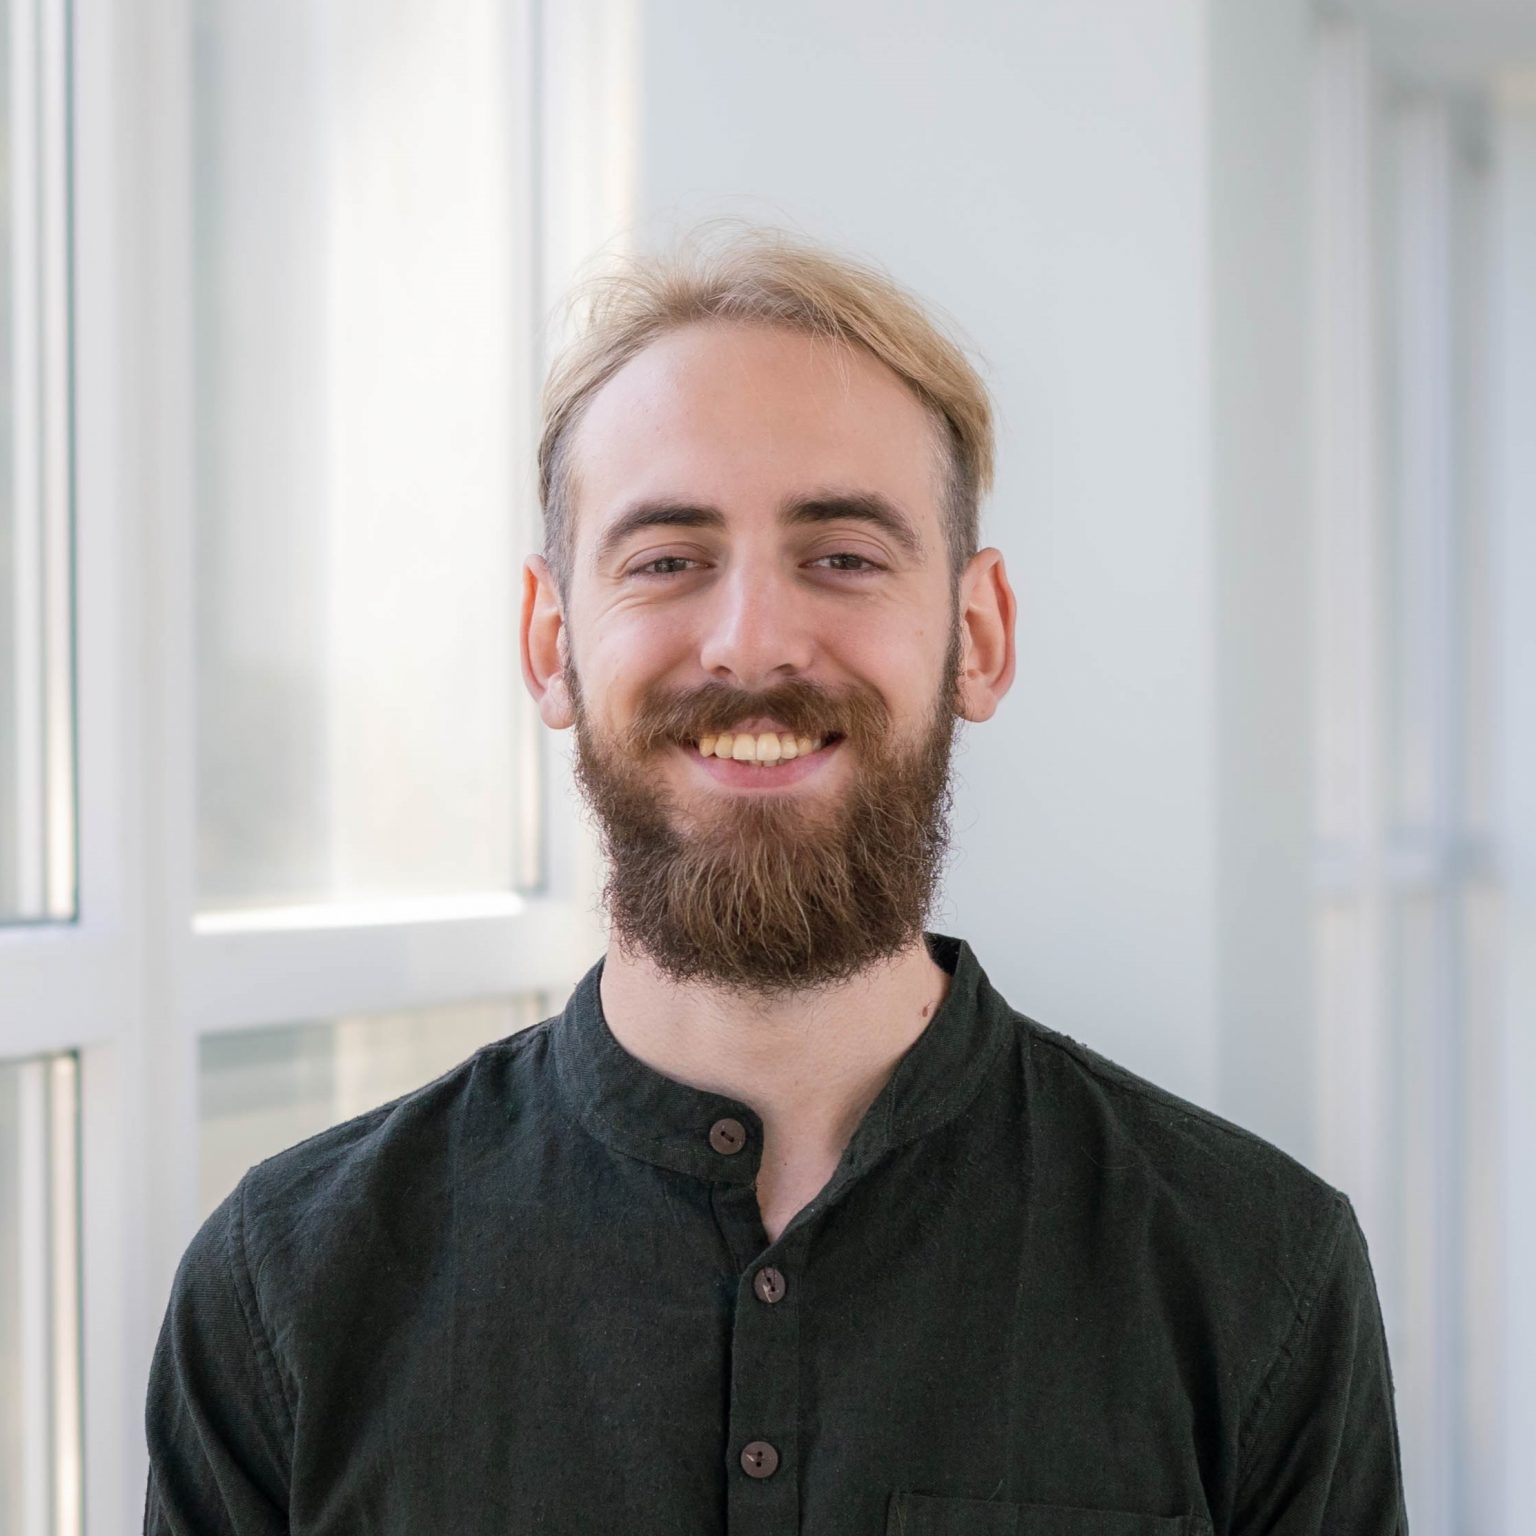
Oskars Vismanis
Mg. sc. ing.
Researcher
Oskars Vismanis is a researcher at the Institute of Electronics and Computer Science (EDI). He began working at EDI in 2019. In 2022, he obtained a professional bachelor’s degree in the program “Adaptronics,” and in 2024, a master’s degree in engineering sciences in the program “Intelligent Robotic Systems” at Riga Technical University (Riga, Latvia). He is currently pursuing doctoral studies in the program “Computer Science and Information Technology” at the same university.
His main research areas include robotics, such as robotic automation, general robotic functions, robot autonomy, as well as robot-to-robot and human-robot interaction. His current scientific work is primarily focused on the exploration and development of generally applicable functions for use in partially defined or undefined environments, which is also the topic of his dissertation.
Recipient of the “Latvenergo” award for one of the best theses in 2022, and the Latvian Academy of Sciences (LAS) award for one of the most significant achievements in Latvian science in 2024.
Outside of academia, Oskars is also an active cultural contributor, playing drums in several bands, creating and performing original music, and occasionally playing well-known songs for event audiences. He is also passionate about reading, maintaining an active and healthy lifestyle, and prototyping robots and other devices.
Projects
7 results
- Human-inspired Advanced Machine Intelligence for accelerating European AI innovation, cooperation and industrial adoption (HumAMI) 01.09.2026 – 31.08.2029 Completed
- Artificial Intelligence using Quantum measured Information for realtime distributed systems at the edge (A-IQ Ready) 01.01.2023 – 31.12.2025 Completed
- Edge AI Technologies for Optimised Performance Embedded Processing (EdgeAI) 01.12.2022 – 31.12.2025 Completed
- Smart Materials, Photonics, Technologies, and Engineering Ecosystem (MOTE) 01.01.2023 – 31.12.2024 Completed
- Development of microrobot based on visual recognition and machine learning for manipulation of individual living cells (RoVam) 01.01.2021 – 31.12.2023 Completed
- Vision, Identification, with Z-sensing Technology and key Applications (VIZTA) 01.05.2019 – 31.10.2022 Completed
- Artificial Intelligence for Digitizing Industry (AI4DI) 01.05.2019 – 31.05.2022 Completed
Publications
- 2025
Correction to: Towards Open-Set NLP-Based Multi-Level Planning for Robotic Tasks(opens in a new window)
Peteris Racinskis, Oskars Vismanis, Toms Eduards Zinars, Janis Arents, Modris Greitans
Applied Sciences (Switzerland), Vol. 15 (5), MDPI
- 2025
Model Selection and Prompting Strategies in Resource Constrained Environments for LLM-based Robotic System(opens in a new window)
Toms Eduards Zinars, Oskars Vismanis, Peteris Racinskis, Janis Arents, Modris Greitans
Charting the Intelligence Frontiers Edge AI Systems Nexu, p. 147-165, River Publishers Series in Communications and Networking
- 2024
Towards Open-Set NLP-Based Multi-Level Planning for Robotic Tasks(opens in a new window)
Peteris Racinskis , Oskars Vismanis , Toms Eduards Zinars , Janis Arents and Modris Greitans
Applied Sciences, Vol. 14 (22), p. 10717, MDPI
- 2023
Natural Language Conditioned Planning of Complex Robotics Tasks(opens in a new window)
Toms Eduards Zinars, Oskars Vismanis, Peteris Racinskis, Janis Arents, Modris Greitans
Advancing Edge Artificial Intelligence, p. 131-152, River Publishers Series in Communications and Networking
- 2023
Supplementation of synthetic object replicas for increasing precision of microrobot trajectory keypoints(opens in a new window)
M. Laizans, J. Arents, O. Vismanis, V. Bučinskas, A. Dzedzickis, and M. Greitans.
Robotic Systems and Applications, Vol. 3 (1), p. 47-58, JVE International Ltd.