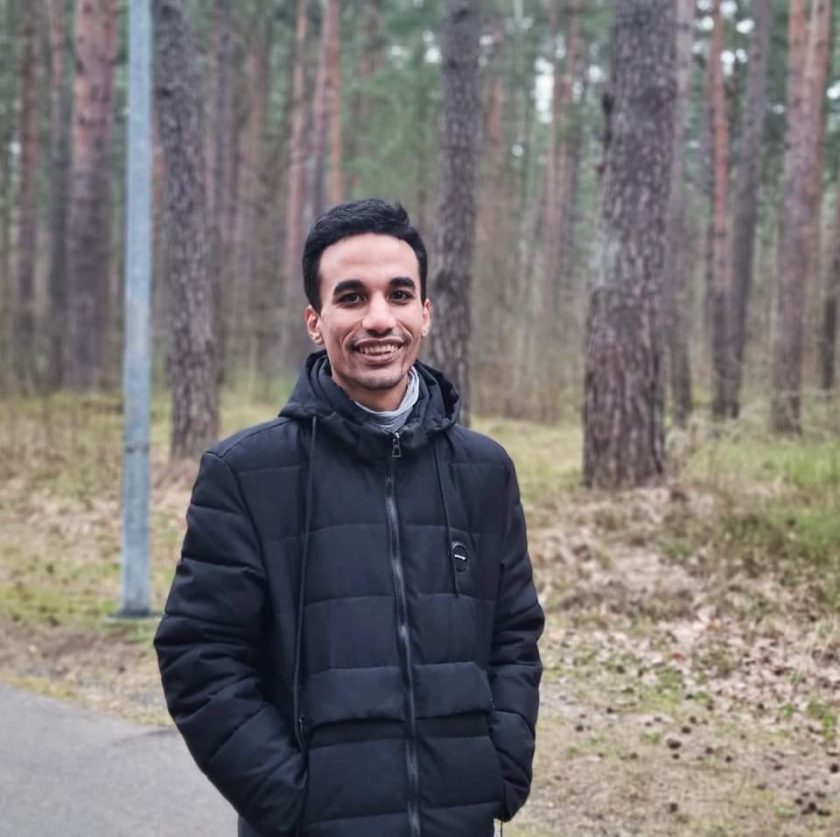
Aly Oraby
Former research assistant
Aly Oraby has been working in EDI since 2020, with main research interests:
-Control Theory: State-space control, Nonlinear control (Lyapunov based techniques), Optimal control (LQR-Trees, MPC) and Force control, -Data driven learning based techniques for robot control (RL).
Mainly working on applying model-based and data-driven methods in motion planning and control in industrial settings, in the Technology Readiness Levels (TRL) 3 to 7.
Projects
3 results
Publications
- 2022
Construction and benchmark of an autonomous tracked mobile robot system(opens in a new window)
Ahluwalia Vaibhav, Arents Janis, Oraby Aly, Greitans Modris
Robotic Systems and Applications, Vol. 2 (1), p. 15-28, JVE Journals
- 2021
Human–Robot Collaboration Trends and Safety Aspects: A Systematic Review(opens in a new window)
Janis Arents, Valters Abolins, Janis Judvaitis, Oskars Vismanis, Aly Oraby, Kaspars Ozols
Journal of Sensor and Actuator Networks, Vol. 10 (3), p. 48, MDPI