Robotics and Machine Perception laboratory
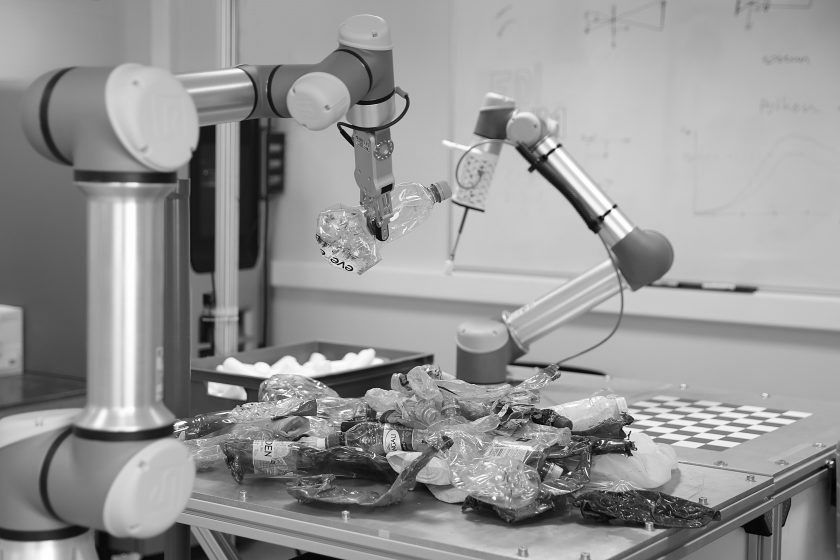
The RuM laboratory develops technologies that enable computerized systems to perceive the world, interpret it, make decisions, and act. We believe that robotics, artificial perception, and artificial intelligence will play an increasingly important role in human development, both in everyday life, industry and economy, as well as politics. EDI RuM's goal is to become a significant player in shaping this future. A player whose research results and developed technologies are not only valued in their scientific field but also promote human welfare, safety, and health. So far, we have developed and adapted our laboratory technologies for various applications in the fields of medicine, industry, agriculture, and mobility.
Keywords:
- machine learning, deep neural networks, synthetic training data
- artificial intelligence - explainable, generative, physics-informed
- automation, industrial robots, real-time control, mobile robots
- embedded intelligence and computer vision
- program synthesis
The laboratory consists of four research groups - three of which focus on different aspects of artificial intelligence and one specializes in robotics research.
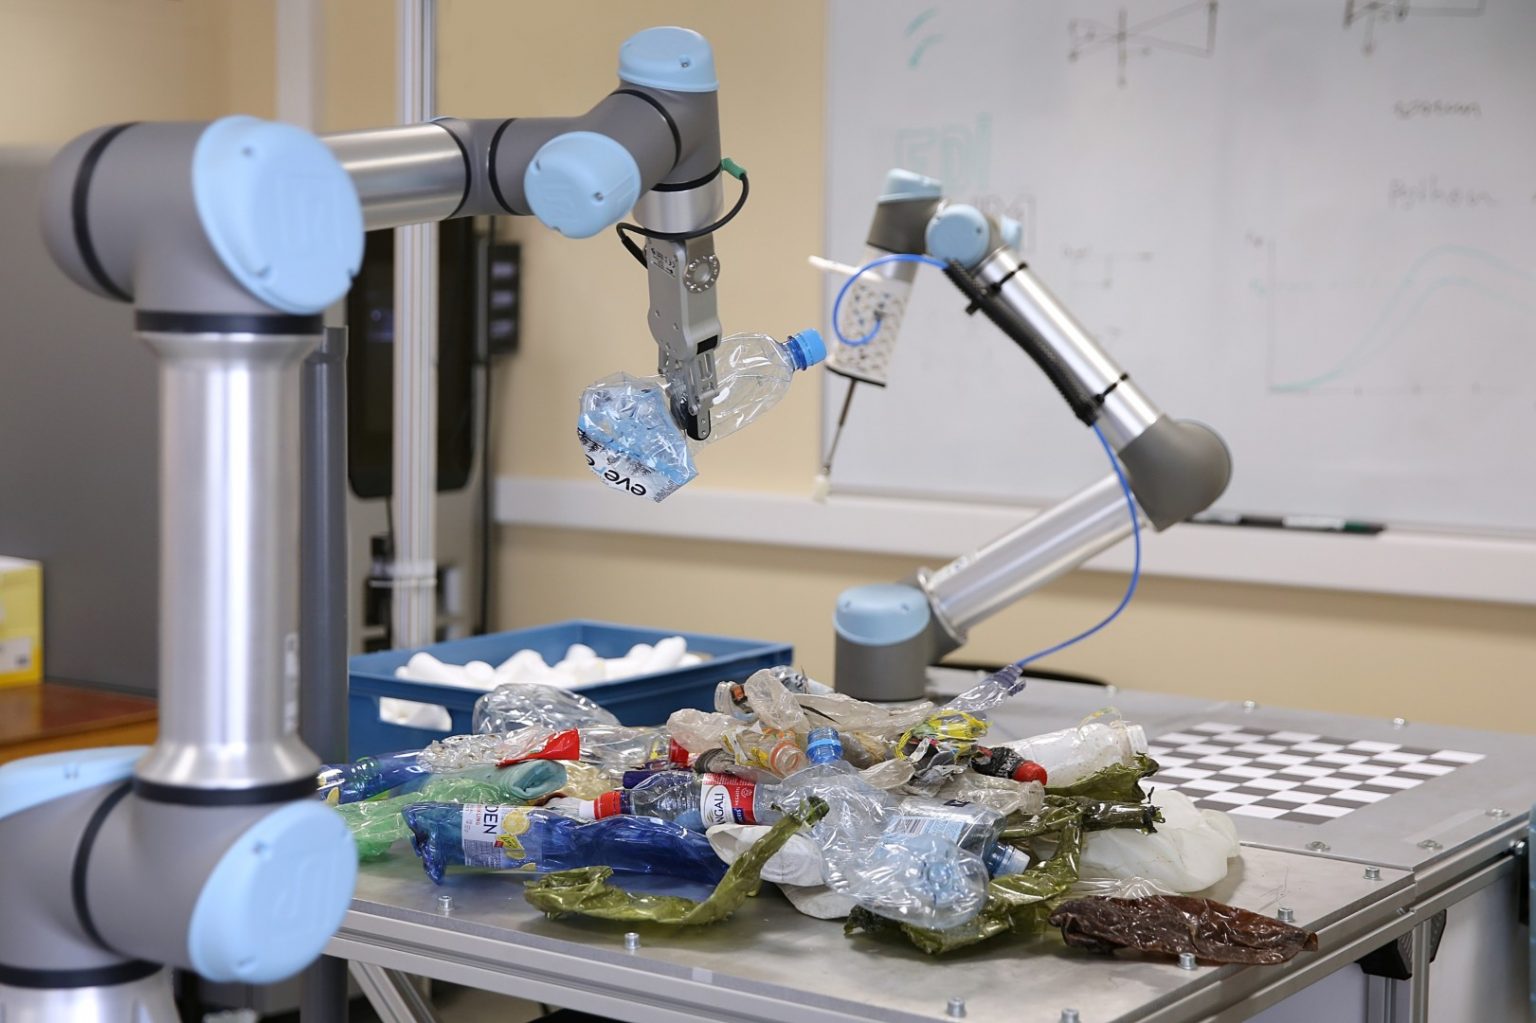
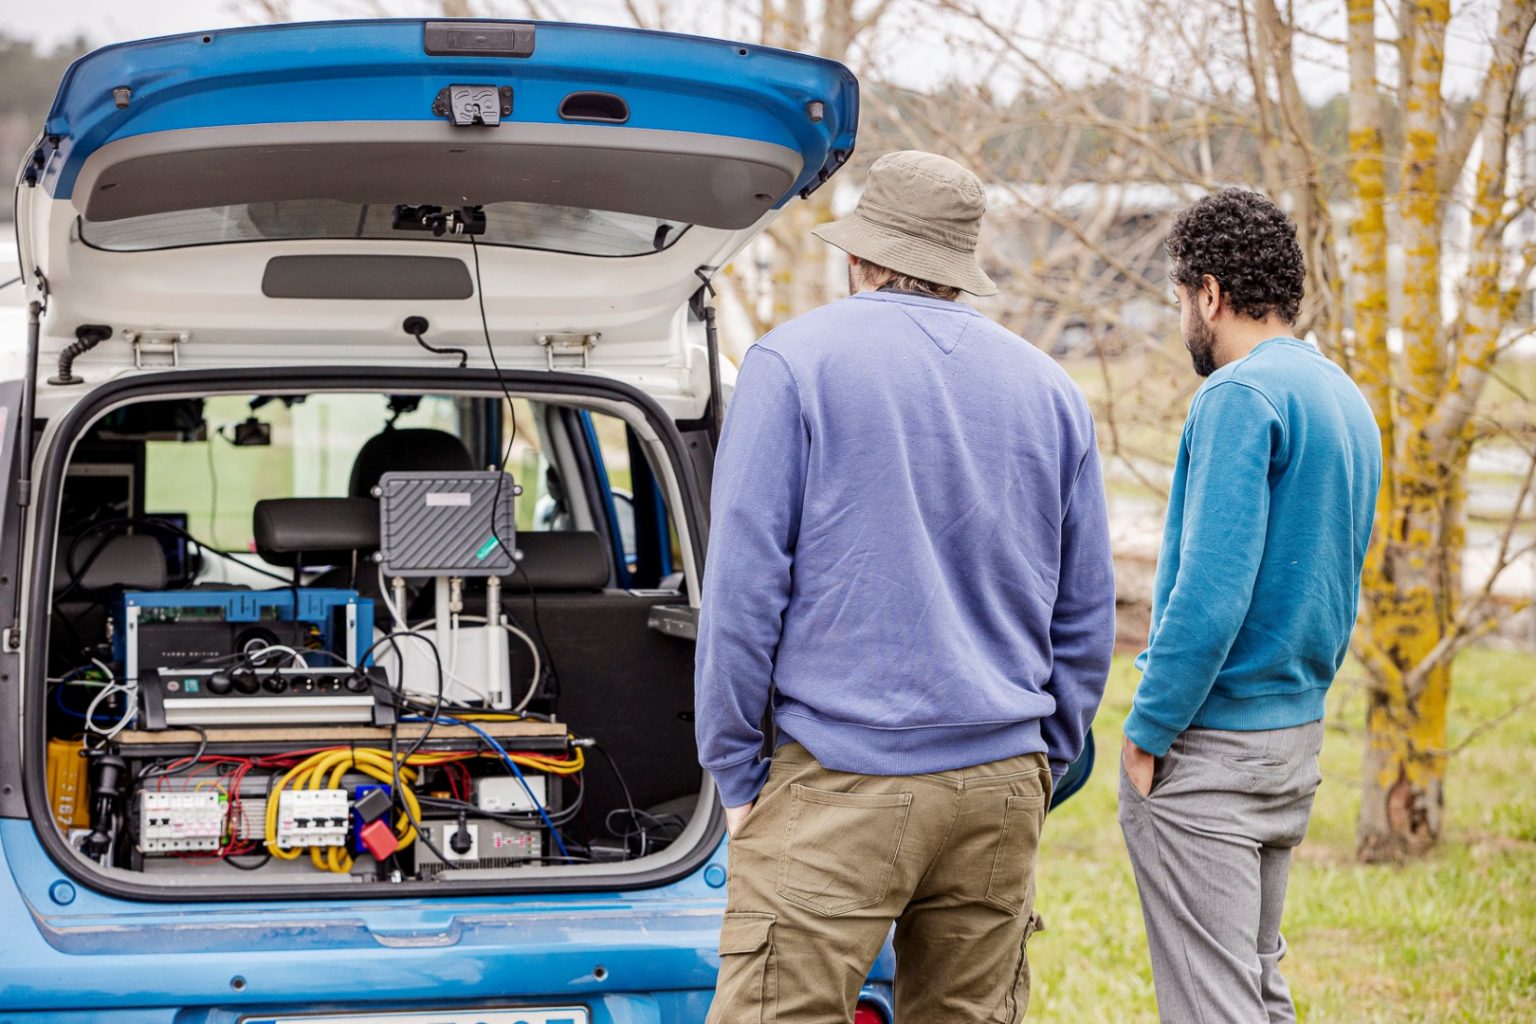
The robotics group led by Ph.D. Jānis Ārents has long-term goals aimed at enabling robots to operate effectively in complex, unstructured environments and interact seamlessly with humans. To achieve this, our work is focused on developing fundamental autonomous mobile navigation capabilities in unstructured environments, as seen in projects like VIZTA, EdgeAI, and MOTE, which explore the use of computer vision and other sensor modalities for perception and semantic scene interpretation. The main goal is to equip robots with the ability to perform general-purpose manipulation and interaction, as illustrated by our work in industrial manipulation within TRINITY and IMOCO4.E, as well as our efforts to facilitate robot-human interaction through projects like AI4DI. This involves not only enhanced perception but also the development of high-level reasoning and task execution, where projects like EdgeAI focus on parsing natural language instructions and grounding them in environmental context using compact, interpretable AI models. Furthermore, we are committed to integrating advanced perception and sensors, including unconventional modalities, with projects like MOTE and EdgeAI adapting open-ended semantic perception to real-world conditions and real-time constraints, allowing for rapid integration of new observations and task-specific information extraction, such as traversable ground segmentation. Our work in recent years, including the development of semantic scene interpretation (MOTE), natural language grounding (EdgeAI), and human interaction (AI4DI), has directly contributed to these goals, enabling robots to understand and operate in open, dynamic environments. We have also focused on developing perception systems that can operate effectively under real-world conditions and real-time constraints, as demonstrated in MOTE and EdgeAI, and creating planning systems that can understand natural language instructions and ground them in the environment using efficient AI models, which is a key aspect of EdgeAI. With these ongoing efforts, we are shaping a future where robots can operate autonomously and collaboratively across a wide range of complex real-world scenarios.
Dr. sc. comp. Kaspars Sudars' group aims to develop better artificial intelligence that leads to scientific excellence, as well as develop AI-based technology that leads to commercialization opportunities. The main theme of the group is explainable artificial intelligence and its methods. In this direction, the group researches fundamental AI models for intelligent system development and uses explainable artificial intelligence to identify relevant data features responsible for AI decision-making. Explainable AI is particularly important in healthcare applications, for which the group has conducted national grant projects OSTAK and LU-AIDA. The group also trains deep neural network models in various industry applications with a high technology readiness level (TRL).
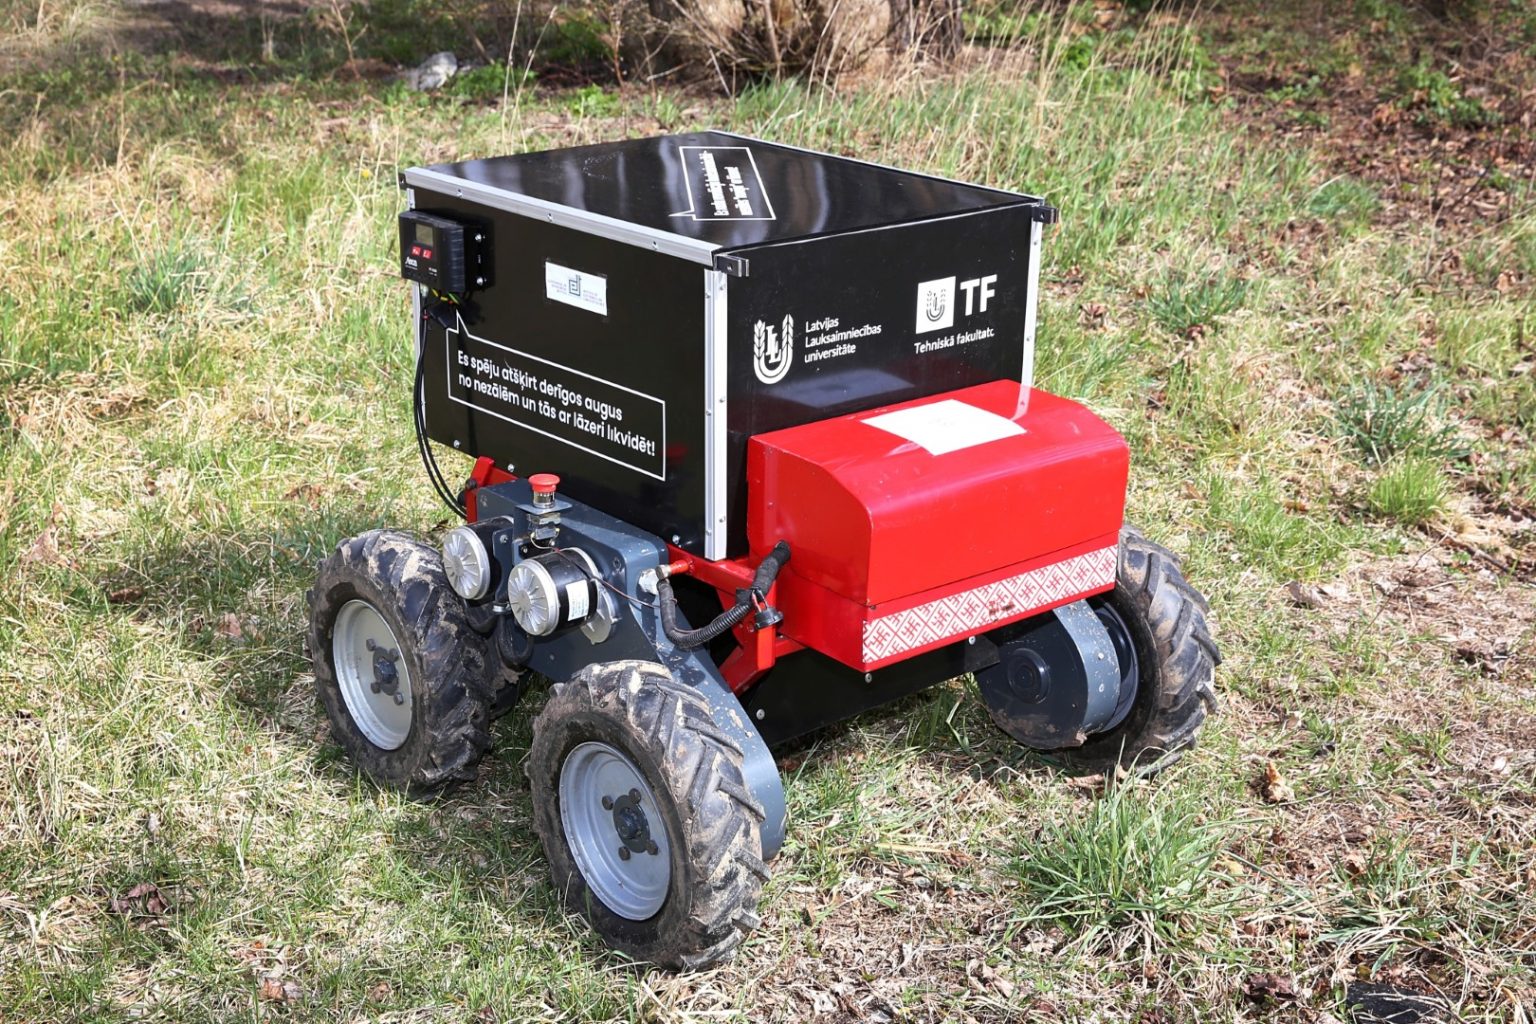
The general scientific direction of the group led by Dr. sc. comp. Kārlis Freivalds is machine learning and artificial intelligence. An additional direction is the creation and application of various mathematical algorithms and the creation of innovative devices based on mathematical algorithms. The most important application currently is in robotics, for example within the international project AIMS5.0. Additionally, the group works with fundamental artificial intelligence topics - physics-informed AI and program synthesis.
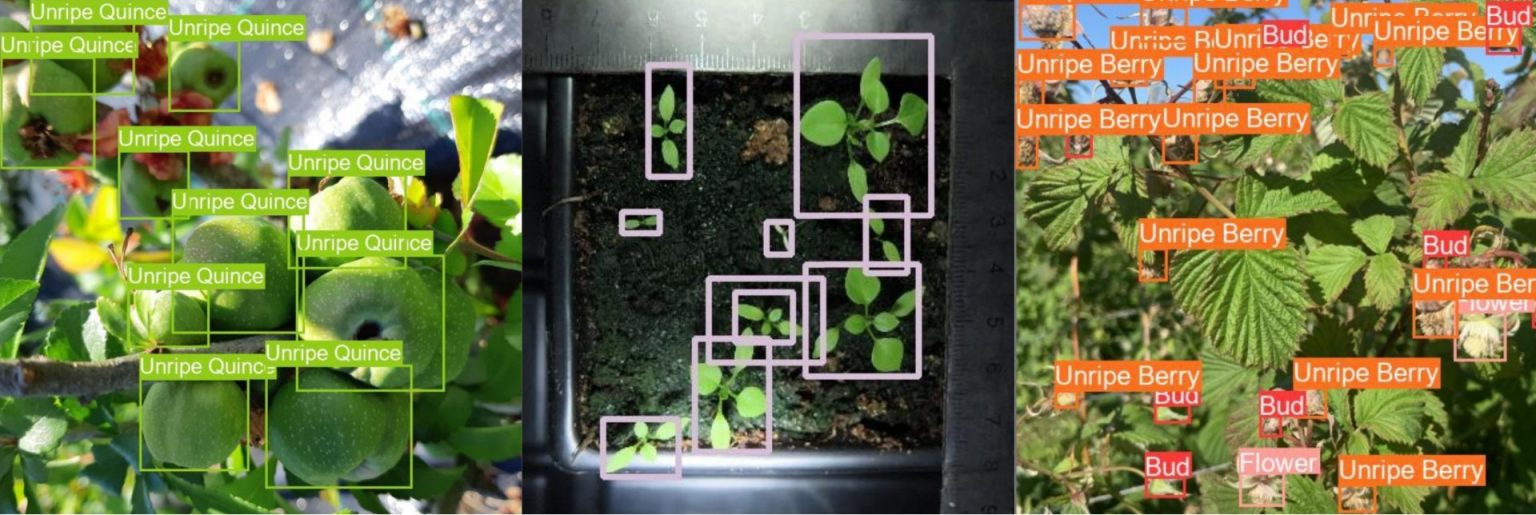
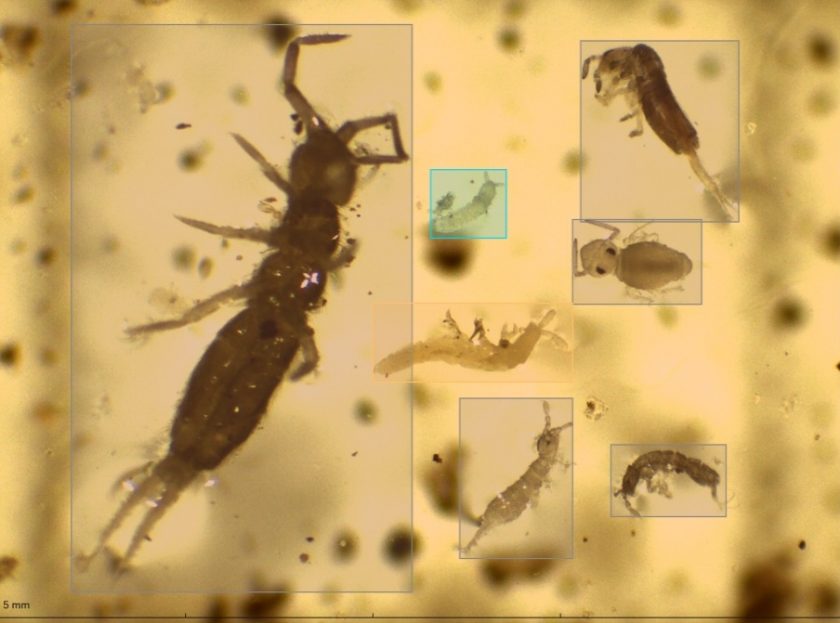
The laboratory head Dr. sc. ing. Roberts Kadiķis' group works on solving computer vision tasks (object detection, image classification, and segmentation) using both machine learning methods and classical image processing approaches. A significant research area is generative AI (generative adversarial networks, diffusion models), which we use for generating synthetic training data. For example, within the ERDF project AimOOC, generative AI was used to synthesize images of organs cultivated on chips, which were then used to train image classifiers for automating the cultivation process. The group actively seeks new applications for generative AI, resulting in solutions such as virtual medical image staining (LZP project HAVeT-AI) and making 3D modelled synhtetic data look more like real images. Models whose perception capabilities have been enhanced with various data synthesis and data augmentation methods are further applied in mobile systems (projects COMP4DRONES, Augmented CCAM), industrial robot systems (VIZTA IMOCO4.E), and for medical image analysis.
Team
Projects
28 results
- Interpretable AI-Powered System for Identification of Bone Metastases in Computed Tomography and Magnetic Resonance Imaging (AIBM) 01.01.2025 – 31.12.2027 Completed
- Soil biological quality index (QBS) determination using machine learning (QBS) 01.01.2025 – 31.12.2027 Completed
- Holographic microscopy- and artificial intelligence-based digital pathology for the next generation of cytology in veterinary medicine (VetCyto) 01.01.2024 – 31.12.2026 Completed
- Artificial Intelligence in Manufacturing leading to Sustainability and Industry 5.0 (AIMS5.0) 01.05.2023 – 30.04.2026 Completed
- Histological recognition and analysis of veterinary tumors surgical margins by using artificial intelligence and multimodal imaging (HAVeT-AI ) 01.02.2023 – 31.12.2025 Completed
- Edge AI Technologies for Optimised Performance Embedded Processing (EdgeAI) 01.12.2022 – 31.12.2025 Completed
- Augmenting and Evaluating the Physical and Digital Infrastructure for CCAM deployment (AUGMENTED CCAM) 01.09.2022 – 31.12.2025 Completed
- New technology to produce hydrogen from Renewable Energy Sources based on AI with optimized costs for environmental applications (HydroG(re)EnergY-Env) 01.05.2022 – 01.05.2024 Completed
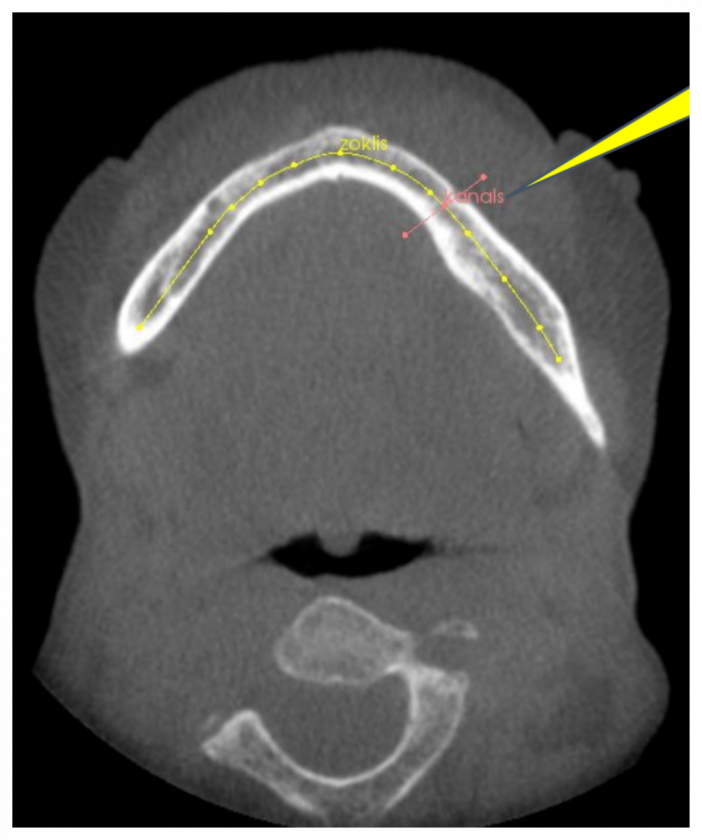
- A Deep Learning Approach for Osteoporosis Identification using Cone-beam Computed Tomography (OSTAK) 01.01.2022 – 31.12.2024 Completed
- AI-improved organ on chip cultivation for personalised medicine (AImOOC) 01.01.2022 – 30.11.2023 Completed
- Intelligent Motion Control under Industry 4.E (IMOCO4.E) 01.09.2021 – 31.08.2024 Completed
- Industrial inertial wireless sensor (IIWS) part 2 01.01.2021 – 30.09.2022 Completed
- Development of microrobot based on visual recognition and machine learning for manipulation of individual living cells (RoVam) 01.01.2021 – 31.12.2023 Completed
- Silicon IP Design House (SilHouse) part 2 01.01.2021 – 30.06.2022 Completed
- Smart non-contact phenotyping of raspberries and quinces using machine learning methods, hyperspectral and 3D images (AKFen) 01.01.2021 – 31.12.2023 Completed
- Artifical intelligence for more precise diagnostics (AI4DIAG) 01.04.2020 – 30.09.2020 Completed
- Framework of key enabling technologies for safe and autonomous drones applications (COMP4DRONES) 01.09.2019 – 31.08.2022 Completed
- Artificial Intelligence for Digitizing Industry (AI4DI) 01.05.2019 – 31.05.2022 Completed
- Vision, Identification, with Z-sensing Technology and key Applications (VIZTA) 01.05.2019 – 31.10.2022 Completed
- Advanced packaging for photonics, optics and electronics for low cost manufacturing in Europe (APPLAUSE) 01.05.2019 – 30.04.2022 Completed
- Development of a robotic weed management equipment (RONIN) 01.01.2019 – 31.12.2020 Completed
- Digital Technologies, Advanced Robotics and increased Cyber-security for Agile Production in Future European Manufacturing Ecosystems (TRINITY) 01.01.2019 – 31.12.2022 Completed
- Low-priced bolus for monitoring rumen parameters and early diagnosis of subacute rumen acidosis (SARA) in cows 01.09.2018 – 31.07.2022 Completed
- Programmable Systems for Intelligence in Automobiles (PRYSTINE) 01.05.2018 – 30.04.2021 Completed
- Real time stereo-vision depth sensing sensor (STRIVE) 29.01.2018 – 31.07.2018 Completed
- Intelligent Motion Control Platform for Smart Mechatronic Systems (I-MECH) 01.06.2017 – 31.05.2020 Completed
- Research on the Development of Computer Vision Methods for Industrial Process Automation (DIPA) 01.11.2016 – 30.11.2018 Completed
- Deep neural network method for improve the accuracy of tracking and classification of vehicles registration plates (DziNTA) 01.09.2016 – 28.02.2018 Completed
Publications
- 2025
Privacy Auditing of Lithium-Ion Battery Ageing Model by Recovering Time-Series Data Using Gradient Inversion Attack in Federated Learning(opens in a new window)
Kaspars Sudars, Ivars Namatēvs, Arturs Nikulins, Kaspars Ozols
Applied Sciences (Switzerland), Vol. 15 (10), MDPI
- 2025
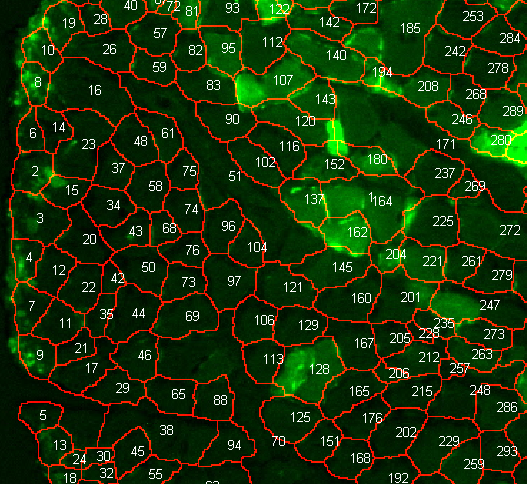
Utilisation of Deep Neural Networks for Estimation of Cajal Cells in the Anal Canal Wall of Patients with Advanced Haemorrhoidal Disease Treated by LigaSure Surgery(opens in a new window)
Fišere, I.; Edelmers, E.; Svirskis, Š.; Groma, V.
Cells 2025, Vol. 14 (7), p. 550, MDPI
- 2025
Multi-Step Object Re-Identification on Edge Devices: A Pipeline for Vehicle Re-Identification
Tomass Zutis, Peteris Racinskis, Anzelika Bureka, Janis Judvaitis, Janis Arents, and Modris Greitans
Charting the Intelligence Frontiers – Edge AI Systems Nexus, p. 233-253, River Publishers
- 2025
Adapting Classification Neural Network Architectures for Medical Image Segmentation Using Explainable AI(opens in a new window)
Arturs Nikulins, Edgars Edelmers, Kaspars Sudars, Inese Polaka
Journal of Imaging, Vol. 11 (2), p. 55, MDPI
- 2025
Privacy Auditing in Differential Private Machine Learning: The Current Trends(opens in a new window)
Ivars Namatevs, Kaspars Sudars, Arturs Nikulins, Kaspars Ozols
Applied Sciences, Vol. 15 (2), p. 647, MDPI
Patents
- 2015
European Patent No. EP2700054 B1
EP2700054 (type: A1, date: 26.02.2014; type: B1, date: 22.04.2015) “System and method for video-based vehicle detection”. Inventors: K.Freivalds, R.Kadikis, M.Greitans. Applicant:
Institute of Electronics and Computer Sciences of Latvia.